Tag: derivatives

  • Bézier Curves: How Four Points Create Beautiful Shapes

    How can four points create a smooth curve? Cubic Bézier curves appear in fonts, vector graphics, animation, and computer-aided design. Their geometry is controlled by just four points, yet they can bend, change concavity, and even cross themselves.

    1. Four control points and one curve

    Let P₀, P₁, P₂, and P₃ be points in the plane. For 0 ≤ t ≤ 1, define

    B(t)=1−t3P0+3t1−t2P1+3t21−tP2+t3P3

    Operations on points are interpreted coordinatewise. The curve begins at P₀ and ends at P₃. The broken line P₀P₁P₂P₃ is the control polygon; the curve need not pass through its middle vertices.

    A new numerical example

    Choose P₀=(0,0), P₁=(2,5), P₂=(6,5), P₃=(8,0). Substitution and simplification give

    x(t)=6t+6t2−4t3, y(t)=15t−15t2

    For example, at t=1/2, the point is B(1/2)=(4,15/4). The symmetry of the control points produces a symmetric arch.

    P0P1P2P3
    Figure 1. Our new example (blue) and its dashed control polygon. The middle control points guide the shape but are not on the curve.

    2. Why the curve stays in the convex hull

    The four scalar weights are (1−t)³, 3t(1−t)², 3t²(1−t), and t³. They are nonnegative for 0 ≤ t ≤ 1, and their sum is

    1−t3+3t1−t2+3t21−t+t3=(1−t+t)3=1

    Proof. By definition, a convex combination of points is a weighted sum with nonnegative weights totaling one. Every B(t) is such a combination of the four control points. Hence the entire curve lies in their convex hull—the smallest convex region containing them. This remains true even if the curve has a loop.

    3. Endpoint tangents

    Differentiate the defining polynomial and group the terms:

    B(t)′=31−t2(P1−P0)+6t1−t(P2−P1)+3t2(P3−P2)

    Consequently,

    B(0)′=3(P1−P0), B(1)′=3(P3−P2)

    Thus, whenever the respective endpoint derivative is nonzero, the tangent line at the start follows P₀P₁, and the tangent line at the end follows P₂P₃. In our example these tangent vectors are (6,15) and (6,−15). Notice that these vectors specify tangent directions, not necessarily the direction of the entire control polygon.

    4. De Casteljau’s algorithm: constructing the curve by interpolation

    For a fixed t, interpolate successively between neighboring control points:

    Qi=1−tPi+tPi+1 (i=0,1,2) Ri=1−tQi+tQi+1 (i=0,1,1) B(t)=1−tR0+tR1

    Why it works. Substitute the formulas for Q₀,Q₁,Q₂ into those for R₀,R₁, then into the last expression. Collecting the coefficients of P₀ through P₃ produces exactly the cubic Bézier formula in Section 1.

    At t=1/2, the first interpolation points are Q₀=(1,5/2), Q₁=(4,5), Q₂=(7,5/2); the next points are R₀=(5/2,15/4), R₁=(11/2,15/4). Their midpoint is (4,15/4), as expected.

    P0P1P2P3
    Figure 2. De Casteljau construction at t=1/2: orange first-stage interpolation, green second-stage interpolation, and the final black point on the curve.

    5. Can a cubic Bézier curve have a loop?

    Yes. Here is an exact construction, deliberately different from the textbook example. Consider the parametric cubic

    x(t)=(t−12)2, y(t)=(t−12)((t−12)2−116)

    At t=1/4 and t=3/4, both expressions yield the same point (1/16,0). Since the parameters are distinct, the curve crosses itself. Its Bézier control points, obtained by converting the cubic power coefficients to Bernstein form, are

    P0=(14,−332); P1=(−112,1396); P2=(−112,−1396); P3=(14,332)
    t=1/4 and 3/4
    Figure 3. An exact cubic loop. The two parameter values 1/4 and 3/4 give the same crossing point.

    6. Joining Bézier curves smoothly

    Suppose one segment ends at P₃ and the next begins at Q₀. Three commonly used continuity conditions are:

    C⁰: P₃=Q₀, so the pieces meet. G¹: their nonzero tangent vectors point in the same direction, so the tangent line has no corner. C¹: their tangent vectors are equal (for the chosen parameterization), so the first derivative is continuous.

    C1: P3=Q0, 3(P3−P2)=3(Q1−Q0)

    For a concrete S-shaped construction, take the first control polygon (0,0),(1,2),(2,2),(3,0) and the second (3,0),(4,−2),(5,−2),(6,0). Both derivatives at the join equal (3,−6), so the pieces meet with C¹ continuity. Equal tangents are stronger than merely collinear tangents.

    join
    Figure 4. Two cubic segments form an S-shaped path and meet with matching derivatives at (3,0).

    7. Curvature, inflection points, and a cubic limitation

    For a regular parametric curve B(t)=(x(t),y(t)), meaning B′(t)≠0, the unsigned curvature is

    κ(t)=|x′(t)y″(t)−y′(t)x″(t)|(x′2+y′2)32

    The numerator is the signed turning determinant. For cubic coordinate polynomials, x′ and y′ are quadratic while x″ and y″ are linear. Although the products appear cubic, their cubic terms cancel, leaving a polynomial of degree at most two. Therefore a nondegenerate regular planar cubic Bézier curve has at most two isolated interior inflection points, since changes in signed curvature can occur only at zeros of this quadratic.

    In our arch example, x′=6+12t−12t² and y′=15−30t, while x″=12−24t and y″=−30. Hence

    x′y″−y′x″=−360+360t−360t2=−360(1−t+t2)<0

    The signed curvature never changes sign: this particular arch has no inflection point.

    Discovery problems

    1. Midpoint identity. Express B(1/2) in terms of the four control points. What happens if P₀+P₃=P₁+P₂?
    2. Convex-hull challenge. Prove that every cubic Bézier curve stays in the convex hull of its control points. Does this still hold if the polygon is nonconvex?
    3. Exact self-intersection. For x(t)=(t−1/2)² and y(t)=(t−1/2)((t−1/2)²−1/16), find two distinct parameter values giving the same point and determine the crossing point.
    4. S-shaped design. Find two cubic Bézier curves from (0,0) to (3,0) and from (3,0) to (6,0) that meet with C¹ continuity and form an S-shaped path.

    Solutions (click to reveal)

    Solution 1: Midpoint identityB(12)=(P0+3P1+3P2+P3)8

    If P₀+P₃=P₁+P₂, this simplifies to B(1/2)=(P₀+P₃)/2, the midpoint of the endpoints.

    Solution 2: Convex hull

    All four Bernstein weights are nonnegative on [0,1] and add to one by the binomial theorem. Therefore B(t) is a convex combination of the control points. The convex hull exists regardless of whether the control polygon is convex, so the conclusion remains true.

    Solution 3: Exact crossing

    At t=1/4 and t=3/4, the squared term is 1/16 and the second factor of y(t) vanishes. Thus both parameter values yield (1/16,0). The two tangent directions are distinct, so this is a genuine transverse crossing.

    Solution 4: A smooth S

    Use P₀=(0,0), P₁=(1,2), P₂=(2,2), P₃=(3,0), followed by Q₀=(3,0), Q₁=(4,−2), Q₂=(5,−2), Q₃=(6,0). The join points agree and 3(P₃−P₂)=(3,−6)=3(Q₁−Q₀). Hence the joined curve is C¹, and the opposite signs of the upper and lower arches create the S shape.

    Bézier curves provide a way to construct smooth paths using a small number of control points. But can a continuous curve fill an entire square? Explore this surprising question in our article on space-filling curves .

    Parametric equations are useful far beyond computer graphics. Another interesting application appears in The Sliding Ladder: Does It Slide or Jump? , where calculus helps describe the motion of a ladder.
  • A Sliding Ladder: Is It Better to Slide or Jump?

    The sliding-ladder problem is one of the most familiar examples of related rates in calculus.

    A ladder leans against a vertical wall. The bottom begins to slide away from the wall, while the top slides downward.

    Usually the textbook asks:

    How fast is the top of the ladder moving?

    But there is a more interesting question:

    If you were on the ladder when it started to slide, what would the mathematics predict as the ladder approached the floor?

    The answer is surprising.

    The Geometry

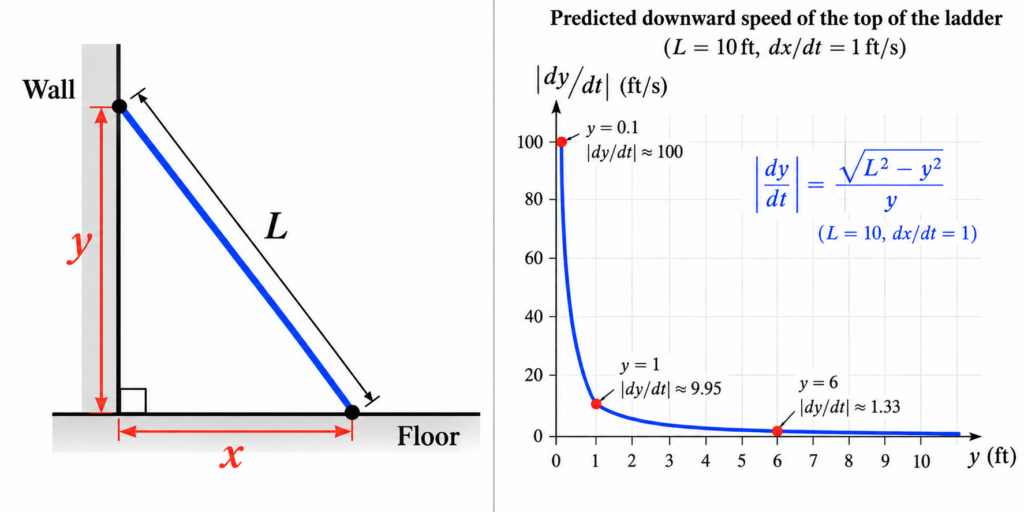
    Suppose the ladder has fixed length L. Let x be the distance from the bottom of the ladder to the wall, and let y be the height of the top of the ladder above the floor.

    Because the ladder, wall, and floor form a right triangle,

    x2 + y2 = L2 .

    As the ladder slides, both x and y change with time. Differentiate with respect to t:

    2x dx dt + 2y dy dt = 0 .

    Dividing by 2 gives

    x dx dt + y dy dt = 0 .

    Therefore,

    dy dt = − xy dx dt .

    This is the standard related-rates formula for a sliding ladder.

    Suppose the Bottom Moves at Constant Speed

    Assume that the bottom of the ladder moves away from the wall at a constant speed v:

    dx dt = v , v>0 .

    Then

    dy dt = − v xy .

    Since

    x = L2 − y2 ,

    we can also write

    dy dt = − v L2 − y2 y .

    The minus sign tells us that the top of the ladder is moving downward.

    What Happens Near the Floor?

    As the top of the ladder approaches the floor,

    y → 0+ , x → L .

    Therefore,

    xy → ∞ ,

    and consequently

    dy dt → −∞ .

    According to this model, the top of the ladder moves downward faster and faster, and its vertical speed becomes arbitrarily large as it approaches the floor.

    A Numerical Example

    Suppose the ladder is 10 feet long and its bottom slides away from the wall at

    dx dt = 1 ft/s .

    When the top is 6 feet above the floor,

    x = 100−36 = 8 .

    Thus,

    dy dt = − 86 = − 43 ft/s .

    Nothing dramatic yet. But when the top is only 1 foot above the floor,

    x = 99 ,

    so

    dy dt = −99 ≈ −9.95 ft/s .

    When the top is only 0.1 foot above the floor,

    dy dt = − 99.99 0.1 ≈ −100 ft/s .

    The closer the top gets to the floor, the larger the predicted downward speed becomes.

    What About dy/dx?

    There is another way to see where this strange behavior comes from. Differentiate

    x2 + y2 = L2

    with respect to x. We obtain

    2x + 2y dy dx = 0 ,

    and therefore

    dy dx = − xy .

    As the ladder approaches the floor,

    dy dx → −∞ .

    Geometrically, this makes sense. The point (x,y) moves along the quarter-circle

    x2 + y2 = L2 ,

    which has a vertical tangent at (L,0) .

    But there is an important distinction: dy/dx is not a velocity.

    The connection with velocity is

    dy dt = dy dx dx dt .

    If the horizontal speed remains positive and constant while dy dx becomes unbounded, then the predicted vertical velocity becomes unbounded as well.

    So Is It Better to Slide or Jump?

    At first sight, the mathematics seems to give a disturbing answer. If you remain with the ladder, the simple model predicts that the downward speed can become enormous near the floor.

    Does that mean you should jump?

    Not so fast.

    The calculation has actually revealed something more interesting: the mathematical model has become physically unrealistic.

    We assumed that the bottom of the ladder continues moving horizontally at a constant speed all the way until the ladder becomes horizontal. A real ladder cannot behave this way.

    A real ladder has mass and rotational inertia. There is friction between the ladder and the floor and between the ladder and the wall. The ladder may lose contact with the wall. A person standing on it changes the center of mass and the forces acting on the system.

    Most importantly, a real physical system cannot produce the infinite vertical velocity predicted by this simplified model.

    So the infinity does not tell us that a real person will hit the floor at infinite speed.

    It tells us that one of our assumptions must fail before that happens.

    Calculus as a Warning About a Model

    This is what makes the sliding-ladder problem more interesting than the usual textbook exercise.

    Related rates correctly tells us that

    dy dt = − xy dx dt .

    Under the additional assumption that the horizontal speed stays constant, it follows that

    | dy dt | → ∞ .

    The calculus is not wrong. The assumption is unrealistic.

    When a correct calculation produces a physically impossible result, the mathematics may be telling us where our model stops being valid.

    The humble sliding-ladder problem is therefore not just an exercise in implicit differentiation. It is also a lesson about the difference between mathematics and the physical world.


    Related: Another example of mathematics revealing the limitations of a model is Population Growth: From Exponential Growth to the Logistic Equation .


    For another example of how calculus models motion in the real world, see Projectile Motion in 3D: Adding Wind and Air Resistance, where the standard projectile problem is extended to include wind and air resistance.

    Another classical motion problem with a surprising answer is the brachistochrone problem. The fastest path is a cycloid when there is no resistance—but what happens when fluid resistance is added?

    Calculus describes many kinds of motion, from mechanical systems on Earth to planets orbiting the Sun. For a fascinating application of derivatives, geometry, and Newton’s laws, read Kepler’s Laws: How Calculus Explains Planetary Motion .